Projects
Research and engineering projects at the intersection of mechanics, AI, and robotics.
surgePDE: Trustworthy Research Agents for PDE Modeling
2026College Research Competition · 2026.06 - 2026.09
Developed a research-agent system that searches for surrogate models for partial differential equations under explicit evaluation and acceptance criteria. The system combines feedback-driven exploration with paired local refinement, using typed model adapters, staged execution, and structured experimental feedback. Experiments on Kuramoto–Sivashinsky forecasting showed that the selected configurations retained their gains after retraining on new trajectories, while paired refinements further improved prediction accuracy.
Seeing the Whole Apple: RGB-D Perception with Shape Completion
2026Required Undergraduate Course, School of Aerospace Engineering · 2026.05 - 2026.09
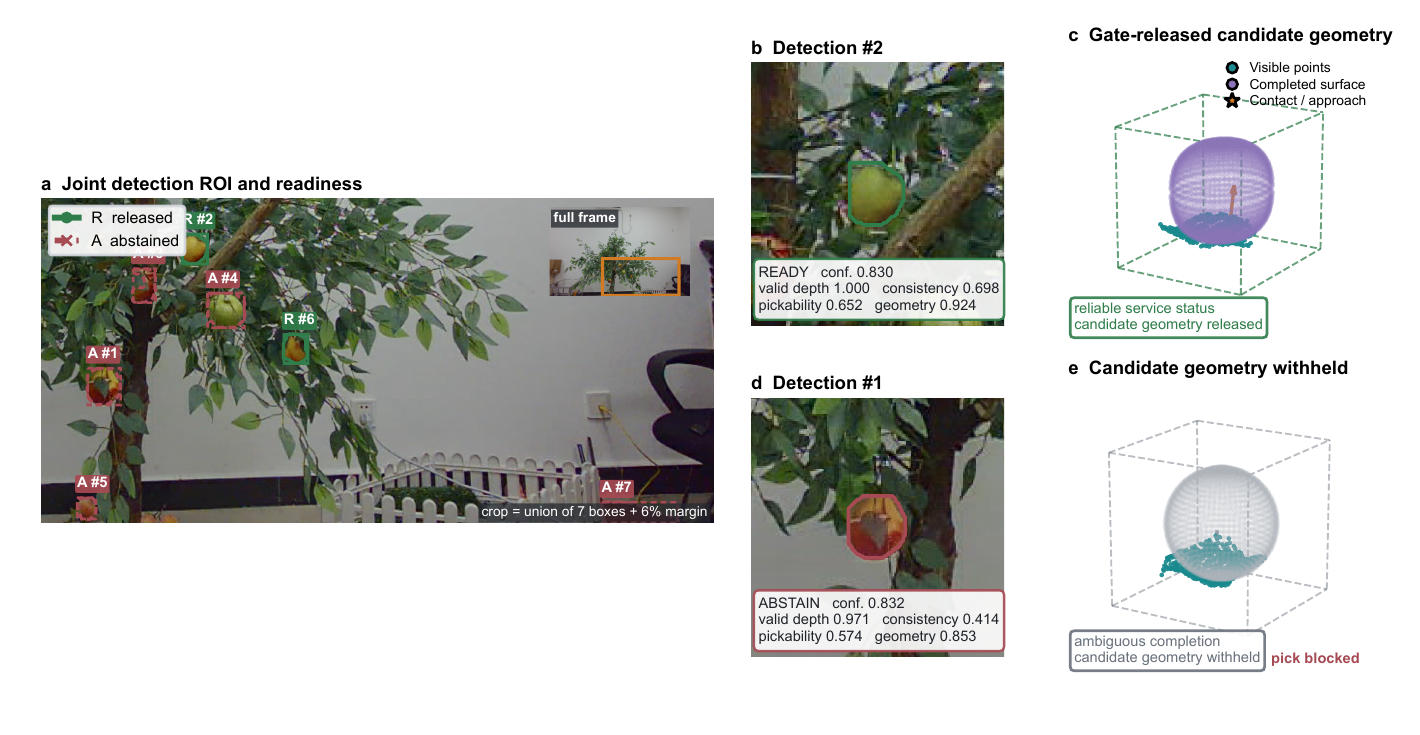
Built an RGB-D perception pipeline for robotic apple harvesting that combines YOLO11s instance segmentation, metric partial point-cloud reconstruction, 3D shape completion, and structured grasp-geometry output. Introduced SQUARE, a lightweight method that augments an instance-fitted superquadric with an observation-aligned radial residual, using measured surfaces for contact and approach estimation while inferring the fruit's hidden centre and extent. Evaluated the system on PFuji and Lab100 apple scans and real-camera scenes through comparisons with geometric and learned completion methods, occlusion and viewpoint stress tests, latency analysis, and explicit abstention when depth or completion was unreliable.
Training Dynamics and Optimization in Consistency Models
2026X-Institute ESRT · 2026.08
Investigated how pair spacing, loss weighting, and optimization affect generative quality, building on established consistency-model frameworks. Combined theoretical analysis with controlled experiments to disentangle training-target and loss-scaling effects, identifying persistent benefits of early loss-weighting adjustments in the studied setting and examining their connection to startup optimization. Contributed to research formulation, experimental design, development of reproducible training and evaluation pipelines, and statistical analysis, consolidating the findings into a systematic account of training-history effects.
Hydrogel Microneedle Robots for Intestinal Peristalsis
2026Student Research Training Program · 2025.02 - 2026.02
Investigated frequency-regulated hydrogel microneedle robots for intestinal peristalsis. Built mechanical models with finite-element-analysis tools and optimized robot designs for locomotion under dynamic peristaltic pressure.
Fixed-Wing UAV Obstacle Avoidance with DRL
2026University Challenge Cup · 2026.01 - 2026.04
Developed a deep-reinforcement-learning framework for fixed-wing UAV obstacle avoidance, using Unreal Engine simulation and incorporating Velocity Obstacle and Dynamic Window Approach methods.